 mozgi
Runway has released the open-source Praxis-1 model for robot control
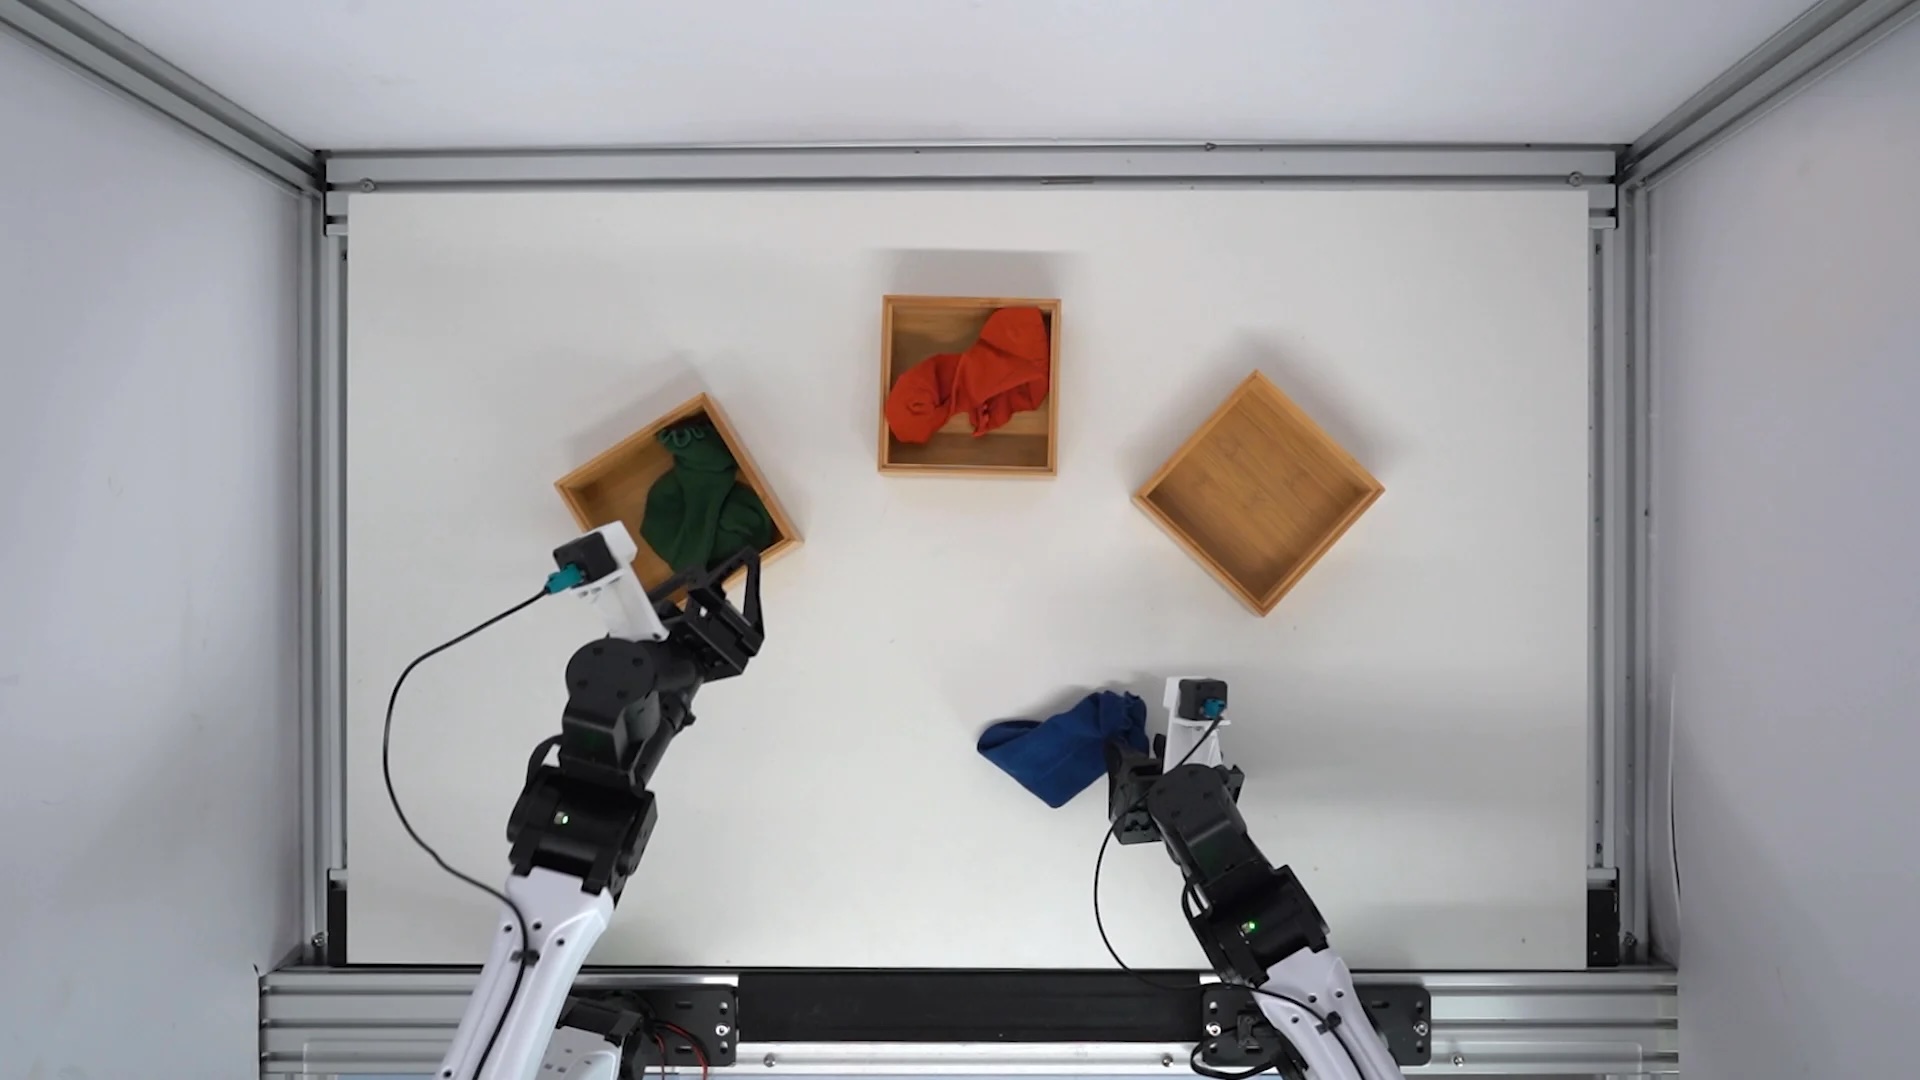
Runway has introduced Praxis-1, a specialized model designed for controlling robotic systems. The developers have released the project's weights and source code under the Apache 2.0 license, making the technology accessible to a wide range of researchers and engineers.
At the core of Praxis-1 is the use of knowledge gained from training on video data to translate these skills into physical robot actions. The model has already demonstrated strong results, taking the lead in the World Action Model category on the RoboLab-120 benchmark developed by Nvidia specialists.
Despite its success in interpreting visual information for manipulation, the current version of the model has functional limitations. Specifically, Praxis-1 is not yet capable of independently planning complex sequences of actions that require multi-step logical reasoning. The developers position this release as an important milestone in integrating video AI into the field of robotics.
For practitioners, this means the arrival of an open tool that allows for the use of accumulated visual data to train agents to interact with the physical world. The availability of the code allows for the integration of the model into proprietary robotic platforms to conduct experiments in motion automation without the need to build proprietary solutions from scratch.
Related news
 Google has introduced the flagship Gemini 4 Hydrogen model
November 12, 2026
 ElevenLabs has released Scribe v3 and Scribe v3 Live speech recognition models
November 12, 2026
 Google has introduced the specialized Gemini Decision 1 model
November 11, 2026
 DeepL has introduced the Aure model to convey emotions in voice translation
November 11, 2026